Skip to content
FREE standard shipping  on orders over US$50+ (Small Items); FREE DHL/Fedex/UPS on orders over US$499 

Start typing to find products

Looking for something? Try searching by category, product name, or brand.

Skip to product info

Tutorial link

ROSMASTER R2 ROS Robot

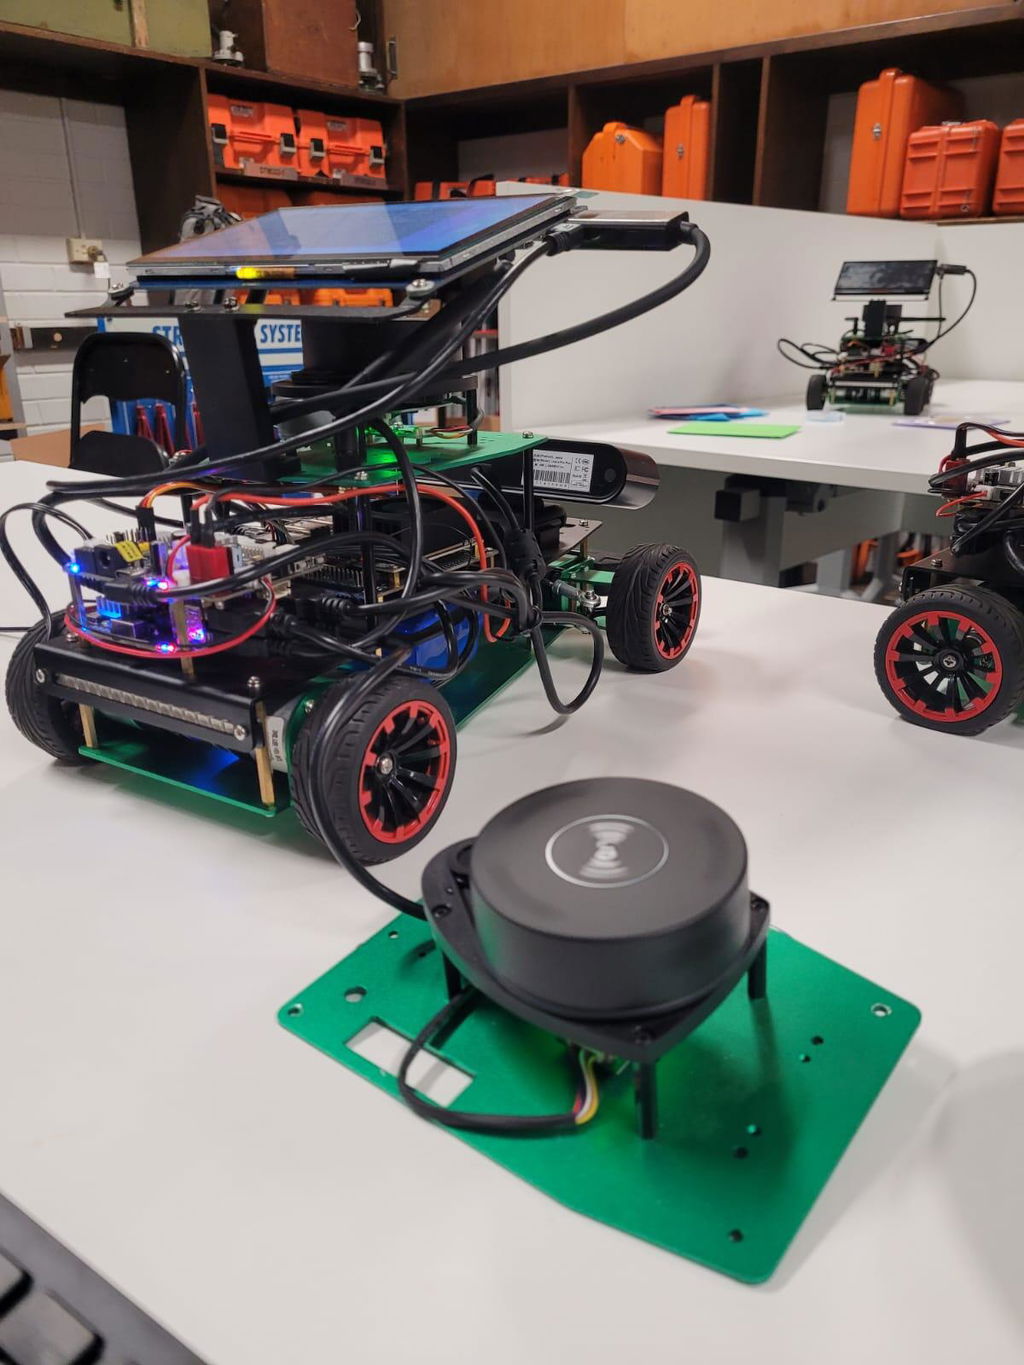
ROSMASTER R2 is a mobile car with AI voice interaction module and Ackerman steering structure developed based on ROS2 system. It supports Jetson NANO(B01/SUB), Jetson Orin NANO SUPER, Jetson Orin NX SUPER and Raspberry Pi5 as main control boards. R2 is equipped with high-performance hardware configurations such as laser radar, depth camera, voice interaction module, 520 motor racing rubber tire, which can realize robot mapping navigation, obstacle avoidance, automatic driving, human feature action recognition, voice interaction control and other functions. It also supports mobile phone APP, wireless handle, ROS operating system, computer keyboard and other remote control methods. And we will provide many lesson teaching videos and many source codes for users' reference.

ROSMASTER R2 Ackerman robot car supports ROS2, Jetson series and RPi 5 developer board, equipped with voice interaction module

ROSMASTER R2 robot car supports Jetson Orin SUPER developer board, AI performance significantly improved by 70%
ROSMASTER R2 provides ROS2 system images and explains what's ROS2 and the prospects and the comparison between ROS1 and ROS2
ROSMASTER R2 choosen: Ackerman vs Mecanum chassis for Autopilot/omnidirectional, depth camera/lidar compatible, 3D mapping

ROSMASTER R2 uses Alloy Al Ackerman chassis with anti-collision bar and anti-skid tire, suitable for auto-pilot and race
ROSMASTER R2 adopts Ackerman steering structure, AI vision and deep learning for autopilot and auto-parking, road detection

ROSMASTER R2 LIDAR and depth camera functions: Gmapping/Cartographer/3D mapping vision, RRT exploration, depth/point cloud image
ROSMASTER R2 AI visual funtions: MediaPipe hand/face/3D detection, AR tags, color/KCF tracking, multi-robot formation navigation & sync control
ROSMASTER R2 remote: iOS/Android apps, FPV handle, Jupyter, keyboard control and ROS system
ROSMASTER R2 robot car provides DeepSeek/Gemma LLM deployment, Rviz simulation control and multimodal visual language models

ROSMASTER R2 Ackerman ROS robot parameter list: Jetson/RPi 5, ROS1/2, depth camera & LiDAR support, anodized aluminum chassis


ROSMASTER R2 ROS2 AI voice interaction Robot with Ackermann structure for Jetson NANO 4GB/Orin NANO SUPER/Orin NX SUPER/RPi 5(Max Speed:1.8m/s)

Vendor: Yahboom

SKU: 6000200594

Regular price $655.00 USD
Main control board: Standard-without
Version: RPi 5-8G
In stock, ready to be shipped

Need help with choosing the right product?

Click here to reach out to one of our experts.

Tutorial link

ROSMASTER R2 ROS Robot

ROSMASTER R2 is a mobile car with AI voice interaction module and Ackerman steering structure developed based on ROS2 system. It supports Jetson NANO(B01/SUB), Jetson Orin NANO SUPER, Jetson Orin NX SUPER and Raspberry Pi5 as main control boards. R2 is equipped with high-performance hardware configurations such as laser radar, depth camera, voice interaction module, 520 motor racing rubber tire, which can realize robot mapping navigation, obstacle avoidance, automatic driving, human feature action recognition, voice interaction control and other functions. It also supports mobile phone APP, wireless handle, ROS operating system, computer keyboard and other remote control methods. And we will provide many lesson teaching videos and many source codes for users' reference.

ROSMASTER R2 Ackerman robot car supports ROS2, Jetson series and RPi 5 developer board, equipped with voice interaction module

ROSMASTER R2 robot car supports Jetson Orin SUPER developer board, AI performance significantly improved by 70%
ROSMASTER R2 provides ROS2 system images and explains what's ROS2 and the prospects and the comparison between ROS1 and ROS2
ROSMASTER R2 choosen: Ackerman vs Mecanum chassis for Autopilot/omnidirectional, depth camera/lidar compatible, 3D mapping

ROSMASTER R2 uses Alloy Al Ackerman chassis with anti-collision bar and anti-skid tire, suitable for auto-pilot and race
ROSMASTER R2 adopts Ackerman steering structure, AI vision and deep learning for autopilot and auto-parking, road detection

ROSMASTER R2 LIDAR and depth camera functions: Gmapping/Cartographer/3D mapping vision, RRT exploration, depth/point cloud image
ROSMASTER R2 AI visual funtions: MediaPipe hand/face/3D detection, AR tags, color/KCF tracking, multi-robot formation navigation & sync control
ROSMASTER R2 remote: iOS/Android apps, FPV handle, Jupyter, keyboard control and ROS system
ROSMASTER R2 robot car provides DeepSeek/Gemma LLM deployment, Rviz simulation control and multimodal visual language models

ROSMASTER R2 Ackerman ROS robot parameter list: Jetson/RPi 5, ROS1/2, depth camera & LiDAR support, anodized aluminum chassis


Questions & Answers loading...